How Robots Learn: Reinforcement Learning vs Imitation Learning
Compare how robots acquire motor skills through Reinforcement Learning (PPO in physics simulators) versus Imitation Learning (Action Chunking from teleoperation).
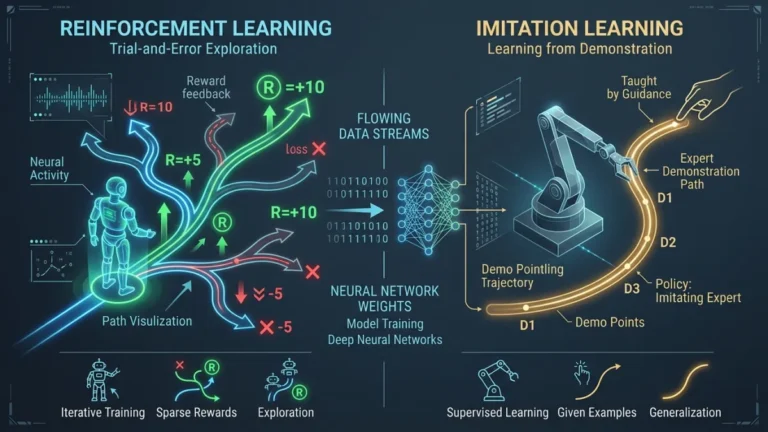
Compare how robots acquire motor skills through Reinforcement Learning (PPO in physics simulators) versus Imitation Learning (Action Chunking from teleoperation).
Learn how Edge AI and TinyML run quantized neural networks locally on microcontrollers like the ESP32-S3 and Arduino Nano 33 BLE Sense with very low latency.