The Sim-to-Real Gap: Why Robots Fail Outside the Lab
Why do robot policies trained in physics simulators fail in the real world? Learn how domain randomization, system identification, and actuator nets bridge the gap.
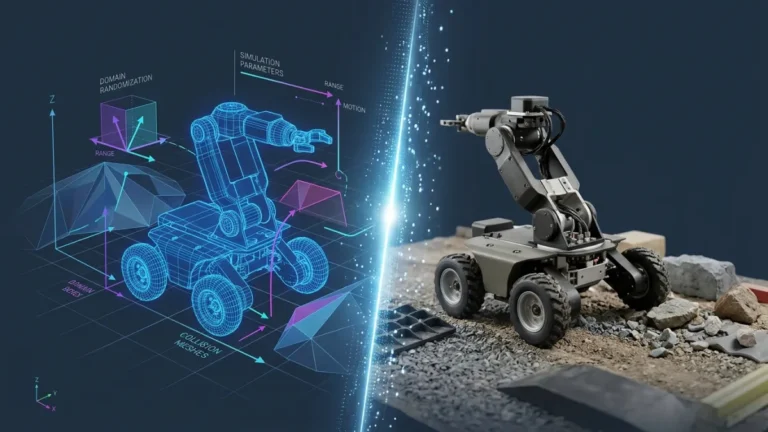
Why do robot policies trained in physics simulators fail in the real world? Learn how domain randomization, system identification, and actuator nets bridge the gap.
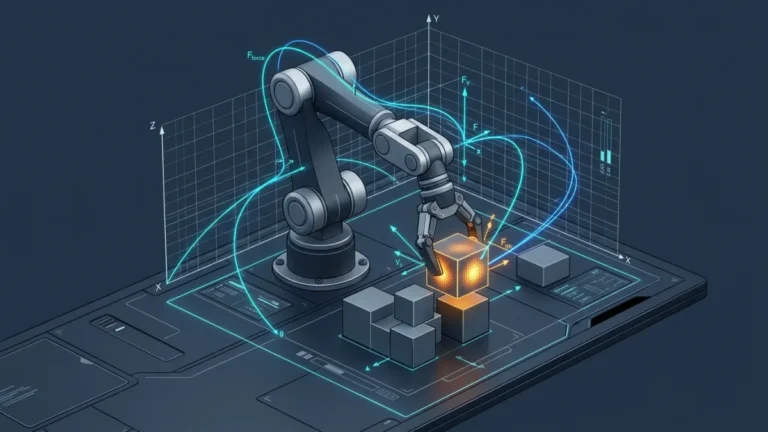
Discover how Physical AI couples multimodal sensors, spatial world models, and Vision-Language-Action (VLA) architectures with real-time robotic control.