The Sim-to-Real Gap: Why Robots Fail Outside the Lab
- The Sim-to-Real Gap is the performance drop that occurs when a control policy trained in a physics simulator is deployed onto physical robot hardware.
- Primary causes: Unmodeled contact friction, deformable surfaces, actuator communication delays, gear backlash, and camera/LiDAR sensor artifacts.
- Proven engineering solutions: Domain randomization, system identification, learned actuator networks, and privileged teacher-student adaptation.
In a computer simulation, a robot can accumulate ten years of walking or grasping experience in a single afternoon without wearing out a single bearing or scratching a lens. Yet when engineers copy that trained neural network onto a physical robot, the machine frequently shakes, slips, or misses its target altogether. In robotics engineering, this mismatch is known as the Sim-to-Real Gap.
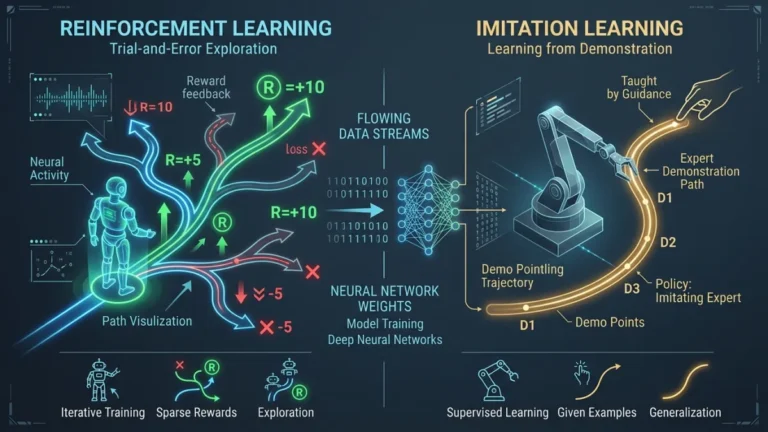
Understanding why simulated policies fail in the real world—and how modern Physical AI teams bridge that divide—is crucial for anyone building or evaluating autonomous systems. Because every physics engine is a mathematical approximation that trades fidelity for computational speed, policies trained via reinforcement learning inevitably exploit shortcuts in the simulator that do not hold true on factory floors.
Three Physical Realities That Simulators Struggle to Model
Even advanced GPU simulators must solve equations of motion in less than a millisecond per step to achieve high training throughput. That speed requirement forces simplified approximations across three critical subsystems:
1. Contact Mechanics, Micro-Slip, and Deformable Materials
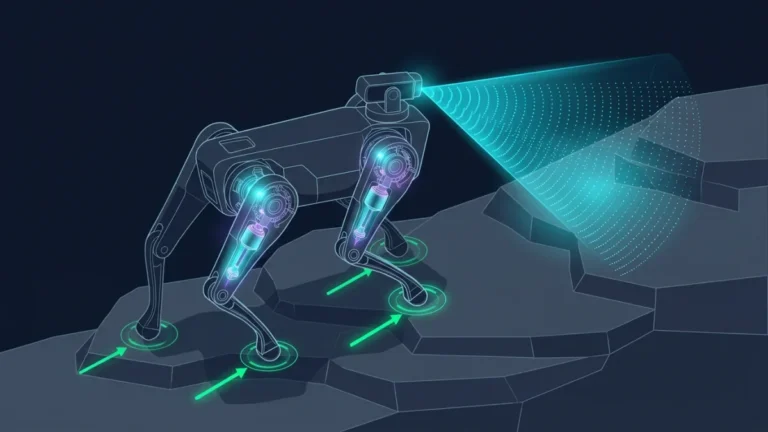
Most robotics simulators approximate objects as perfectly rigid bodies governed by simplified Coulomb friction cones. In the physical world, nothing is strictly rigid. Rubber robot fingertips compress viscoelastic pads, cardboard boxes flex under grip pressure, and floor dust alters static versus dynamic friction (the Stribeck effect) from step to step. When a policy relies on an idealized friction coefficient, a tiny unmodeled tangential slip causes a grasp or footstep to fail.
2. Actuator Dynamics, Backlash, and Communication Latency
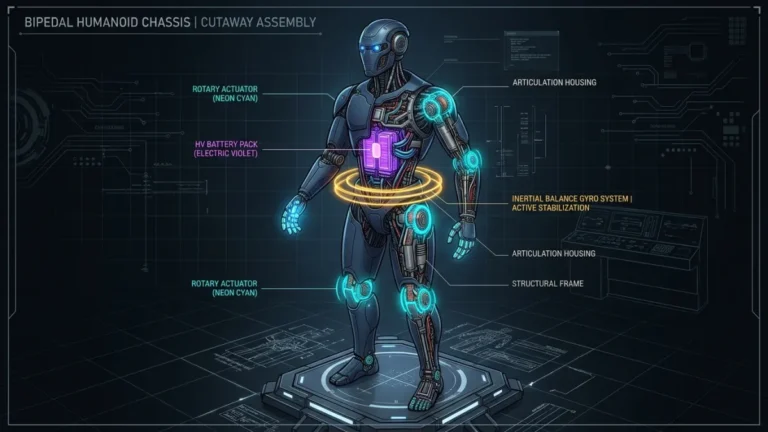
In a naive simulation, if a neural network requests $12\text{ Nm}$ of torque at timestep $t$, the virtual joint applies exactly $12\text{ Nm}$ instantaneously. On a physical humanoid or quadruped robot, commands travel across CAN-FD or EtherCAT buses with 1 to 5 milliseconds of transport jitter. Inside the actuator, strain-wave or planetary gears exhibit non-linear friction, deadzones, and backlash, while copper motor windings heat up during operation—shifting electrical resistance and torque constants over time.
3. Optical and Inertial Sensor Imperfections
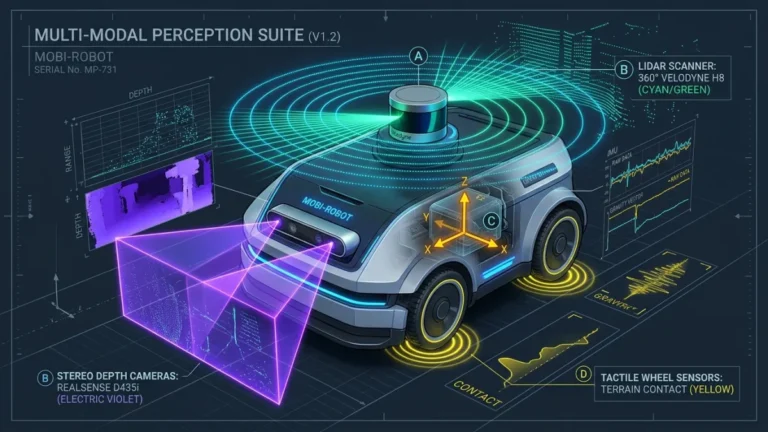
Simulated depth cameras often return mathematically clean distance arrays via raycasting. Physical stereo and time-of-flight sensors, by contrast, suffer from missing depth pixels on shiny metallic parts, transparent plastics, dark light-absorbing fabrics, and motion blur. Similarly, real-world IMUs and force sensors experience structural frame vibrations when legs impact the ground.
How Engineers Bridge the Sim-to-Real Gap
Rather than waiting for infinitely accurate simulators, robotics researchers have developed four complementary techniques that force neural policies to remain robust when transferred to physical hardware:
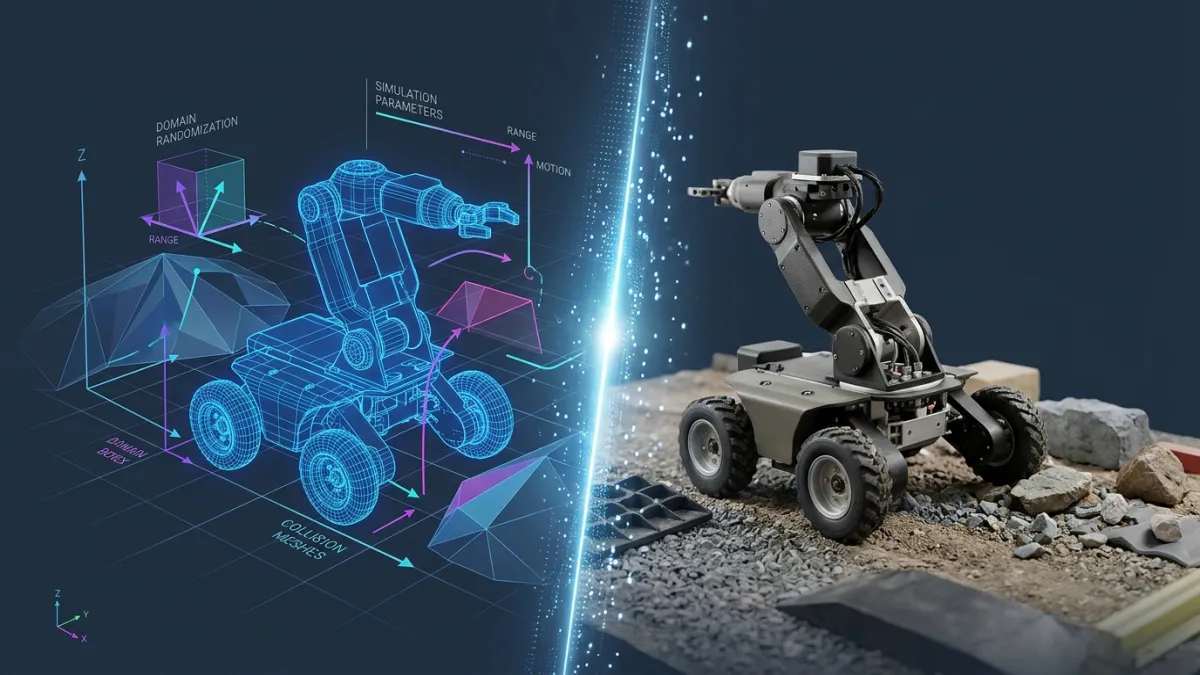
- Domain Randomization: Pioneered in Tobin et al., Domain Randomization for Transferring Deep Neural Networks from Simulation to the Real World (arXiv:1703.06907), this technique deliberately varies simulator parameters on every training episode. Visual textures, camera positions, link masses ($\pm 20\%$), surface friction coefficients, motor strengths, and communication delays are sampled randomly. If the distribution of simulated environments is wide enough, the policy treats the real physical world as just one more variation it already knows how to handle.
- System Identification and Learned Actuator Networks: Instead of guessing motor parameters, engineers excite the physical robot’s joints with chirp signals to measure real torque tracking and latency. For complex actuators, teams train a small neural network on real motor log data and plug that actuator net directly into the simulator, as demonstrated in dexterous in-hand manipulation transfer research (arXiv:1808.00177).
- Privileged Teacher-Student Adaptation (RMA): During simulation, a “teacher” policy receives privileged ground-truth physics numbers (exact floor friction, payload mass, and external push vectors). Next, a “student” policy is trained to infer those hidden physical properties solely from a short history of its own joint position errors and IMU readings.
- Real-World Fine-Tuning and Residual Learning: As surveyed in Sim-to-Real Transfer in Deep Reinforcement Learning for Robotics (arXiv:2009.13303), deploying a base simulation policy and learning a small residual correction on physical hardware combines simulation speed with real-world precision.
Practical Checklist for Sim-to-Real Deployment
When moving a learned controller from a workstation simulator onto an embedded target or mobile robot, engineering teams follow a strict safety progression:
- Action Rate & Smoothness Penalties: Penalize rapid action changes ($\|a_t – a_{t-1}\|^2$) during training so the policy never commands violent high-frequency torque spikes that overheat real motors.
- Latency Injection: Always inject realistic sensor-to-actuator delay (typically 5 to 20 milliseconds) into the simulation loop before testing on hardware.
- Gantry and Soft Torque Limits: Suspend legged robots from a slack overhead safety hoist and clamp maximum motor current in firmware during initial real-world trials.
This IEEE Spectrum video shows quadruped robots navigating physical obstacle courses where policies must adapt to real-world foot slip and uneven terrain:
From my own experience
[ADD MY EXPERIENCE: Describe a discrepancy you encountered between a simulated robot model (in MuJoCo, Gazebo, or Isaac Sim) and the physical hardware.]
Sources
- Domain Randomization for Transferring Deep Neural Networks from Simulation to the Real World (arXiv:1703.06907) — Foundational research paper introducing domain randomization for zero-shot sim-to-real transfer.
- Learning Dexterous In-Hand Manipulation (arXiv:1808.00177) — Primary research paper detailing large-scale domain randomization and actuator modeling for physical robotic hands.
- Sim-to-Real Transfer in Deep Reinforcement Learning for Robotics: a Survey (arXiv:2009.13303) — Comprehensive peer-reviewed survey of system identification, domain adaptation, and sim-to-real methodologies.
Last updated: November 3, 2026